A syringe-equipped ViperX 300 S arm draws liquid from a vial mounted on a sphere that permits arbitrary orientation. The operator locked all rotational axes once the needle was aligned (axis lock TAP), so both policies were trained on the same clean demonstrations. Ours is Hybrid Imitation Learning on Diffusion Policy with the learned primitive channel; DP is the same Diffusion Policy trained on the same TAP-collected demonstrations without the channel. Seven initial configurations, sampled with the same seed for both policies, each executed three times (21 rollouts per policy): Ours 13 (62%) vs DP 12 (57%) successes. Below, all 21 rollouts per policy: one video per initial configuration, each showing the three repetitions of that configuration back to back.
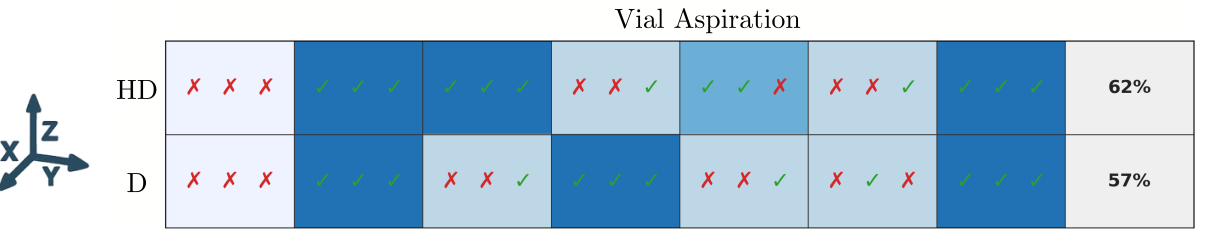
Outcome of all 21 rollouts per policy (pos 1–7, three repetitions each). HD: Ours; D: baseline Diffusion Policy.